- [email protected]
- +91 9151118036
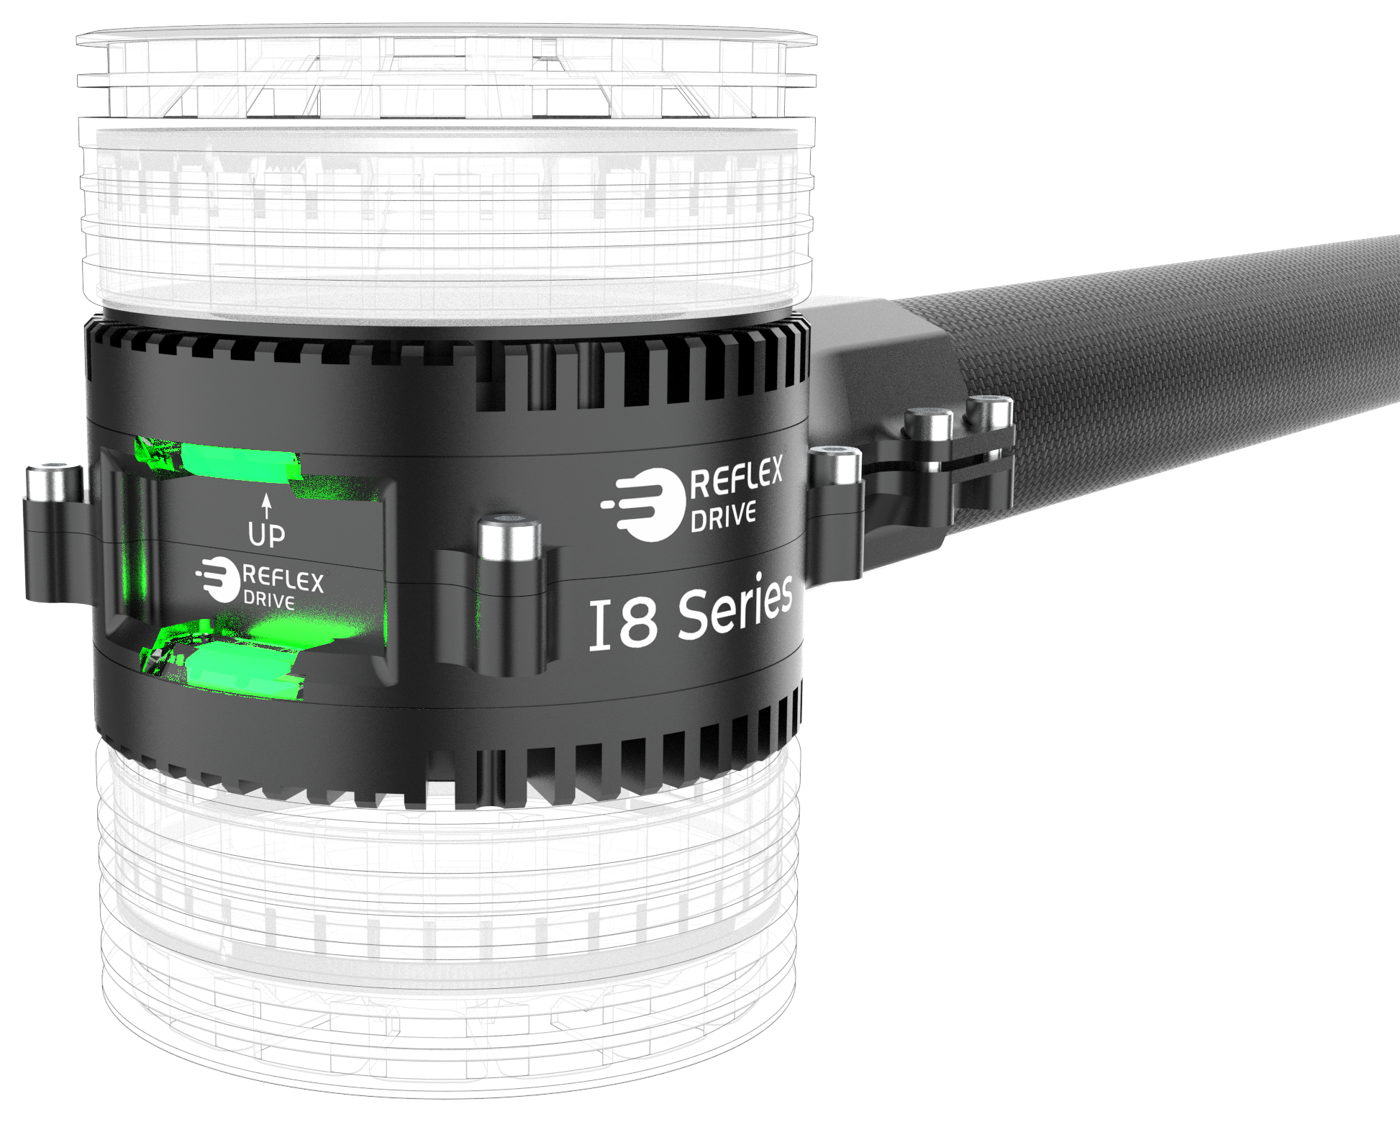
The RD I8 CPU Base with FOC ESC and Encoder is supplied as an integrated base with a FOC ESC (similar to A-Series 120A) with encoder electronic speed controller, for motor manufacturers and UAV OEMs who bring their own motor. The supply covers the ESC and the mounting only. The motor is not included.
The ESC runs on 14S with 40A continuous current and 80A (180 s) peak current, and communicates over PWM and UAV-CAN with telemetry over CAN. This version adds an encoder for motor position feedback. Made in India, with non-China sourced semiconductors.
| S. No. | Parameter | Requirement | Remark |
| 1 | Input Voltage | 14S | |
| 2 | Continuous Current (A) | 40A | |
| 3 | Peak Current (180 s) | 80A (180 s) | |
| 4 | BEC Output Voltage | No | – |
| 5 | Operating Ambient Temperature (℃) | (-20℃) ~(+ 65℃) | ±5℃ |
| 6 | Operating Humidity (%) | 15% ~ 85%RH | ±5%RH |
| 7 | Standby Current (at 48V) | ≤ 80mA | – |
| 8 | Throttle Range | 1050us ~ 1900us | – |
| 9 | Throttle Refresh Frequency | 50 ~ 450Hz | – |
| 10 | Input Signal | PWM & CAN | – |
| 11 | Telemetry | Over CAN only | Voltage, Current, Motor RPM, PCB Temperature, Fault status |
| 12 | Input Signal Isolation | Yes (PWM only) | |
| 13 | Braking Feature | Yes | |
| 14 | Invert Motor Spin | Yes | Using CAN |
| Encoder | Additional encoder interface for motor position feedback | – |
| Dimensions | 103 x 50 x 24 mm | ||
| Weight (Inc. wires) | 222g | ||
| Control Method | Field Oriented Control (FOC) | – | |
| CAN Control | Yes | – | |
| Recommended Motors | RD8015 | – |